
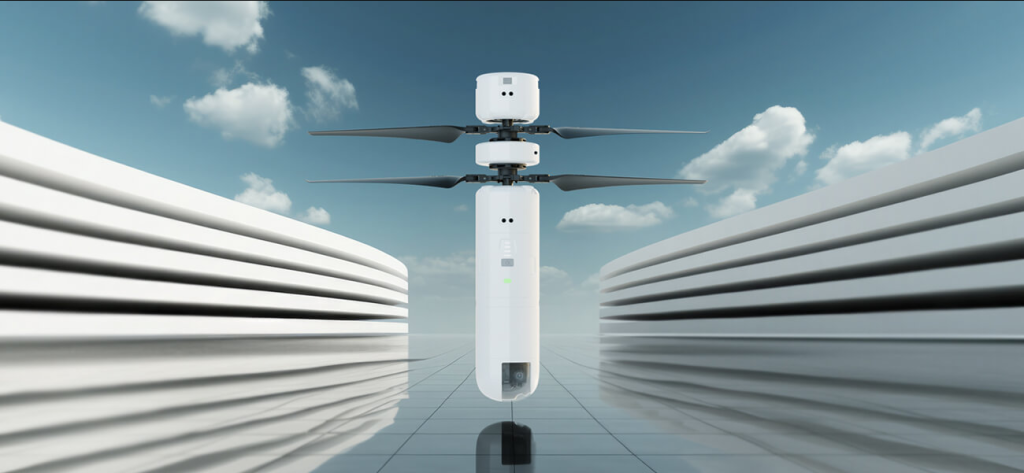
A future-facing scene
By dawn the sky will not feel like empty space; it will feel curated. That is the speculative logic driving how we study loitering munitions and autonomous flight control in FPV combat platforms today. Manufacturers and planners already model scenarios where a single aircraft holds position for minutes while sensors scan a grid, and a strike decision can be executed without the latency of distant command links. This is the terrain where a modern military drone manufacturer calibrates endurance, sensor fusion, and guidance into a seamless system of systems.
Core anatomy: frame, propulsion, and the munition stack
At the heart of any loitering munition is a simple proposition: sustain, sense, and deliver. The airframe favors efficient lift-to-drag, battery or hybrid propulsion tuned for long loiter times, and modular hardpoints for a calibrated payload. Guidance layers sit above: FPV telemetry for real-time operator sight, inertial measurement units for dead-reckoning, and a lightweight terminal seeker for final acquisition. Industry terms like payload, telemetry, and FPV matter because they describe where engineering effort best yields tactical advantage. Recent conflicts — notably the 2020 Nagorno-Karabakh engagements and the 2022–present Ukraine operations — already illustrate how accessible loitering systems change force posture, offering a real-world anchor for strategy and procurement decisions.
Autonomous flight controls: algorithms that think in arcs
Autonomy in this context is not science-fiction autonomy; it’s layered autonomy. Low-level flight controllers stabilize attitude and execute waypoints. Mid-level systems manage loiter patterns, energy budgeting, and sensor cueing. Top-level decision modules apply rules of engagement and mission intent. When neural planners and deterministic guidance coexist, the aircraft can re-plan a strike corridor around emergent threats without human input for milliseconds—short enough to matter. Designers optimize for predictable failure modes: safe termination, graceful descent, or return-to-base. The balance between onboard decision-making and remote oversight is the domain where top military drone manufacturers differentiate technical maturity from mere concept.
Operational patterns and tactical doctrines
Expect three recurring employment patterns to dominate theaters: persistent overwatch, precision single-target engagement, and swarm saturation. Persistent platforms hold target sets until high-confidence sensor cues emerge. Precision strikes use guided terminal seekers to defeat hardened assets. Swarms leverage distributed autonomy and secure mesh links to overwhelm defenses. Each pattern imposes a different engineering priority: endurance for overwatch, seeker accuracy for precision, and resilient networking for swarms. Mistakes are procedural as much as technical—overpacking sensors adds weight; excessive autonomy without rigorous verification invites unintended engagements. Design and doctrine must co-evolve.
Common mistakes and corrective design choices
Teams often repeat avoidable errors: underestimating electromagnetic interference in contested environments, assuming flawless GNSS for navigation, or ignoring thermal signatures that degrade seeker performance. Corrective steps are straightforward: robust inertial navigation fallback, spectral diversification in seekers, and hardened telemetry links with graceful degradation modes. Pay attention to safety nets—geofencing fails; predictable termination modes save collateral risk. —These simple fixes reduce operational surprises and stabilize mission outcomes.
Procurement lens: what to evaluate
Choosing a platform means assessing three core axes. First, system maturity: documented field deployments, firmware update cadence, and supply-chain traceability. Second, interoperability: open APIs for command-and-control, standardized telemetry, and support for allied encryption suites. Third, mission fit: endurance versus payload, seeker type versus target set, and the human-in-the-loop latency your rules of engagement require. Good procurement weighs measurable metrics, not marketing claims.
Advisory — three golden rules for selection
1) Certify mission reliability with live, instrumented end-to-end tests rather than lab demos. Measure time-on-target, seeker lock rate, and failure-mode recovery.
2) Demand layered navigation and secure telemetry by design; redundancy in inertial navigation and encrypted mesh links are non-negotiable.
3) Verify sustainment pathways: parts commonality, OTA update policies, and manufacturer transparency on provenance.
Final reflection
Future airspaces will host systems that think in loops: sense, decide, act, and report. That loop tightens capability and risk at once. Seek platforms that expose their limits honestly and support disciplined oversight. For procurement teams and operators, the objective is clear — choose systems with proven behavior, predictable failure modes, and transparent supply chains. Military Hub synthesizes those signals into actionable insight. Authority affirmed. —end note.